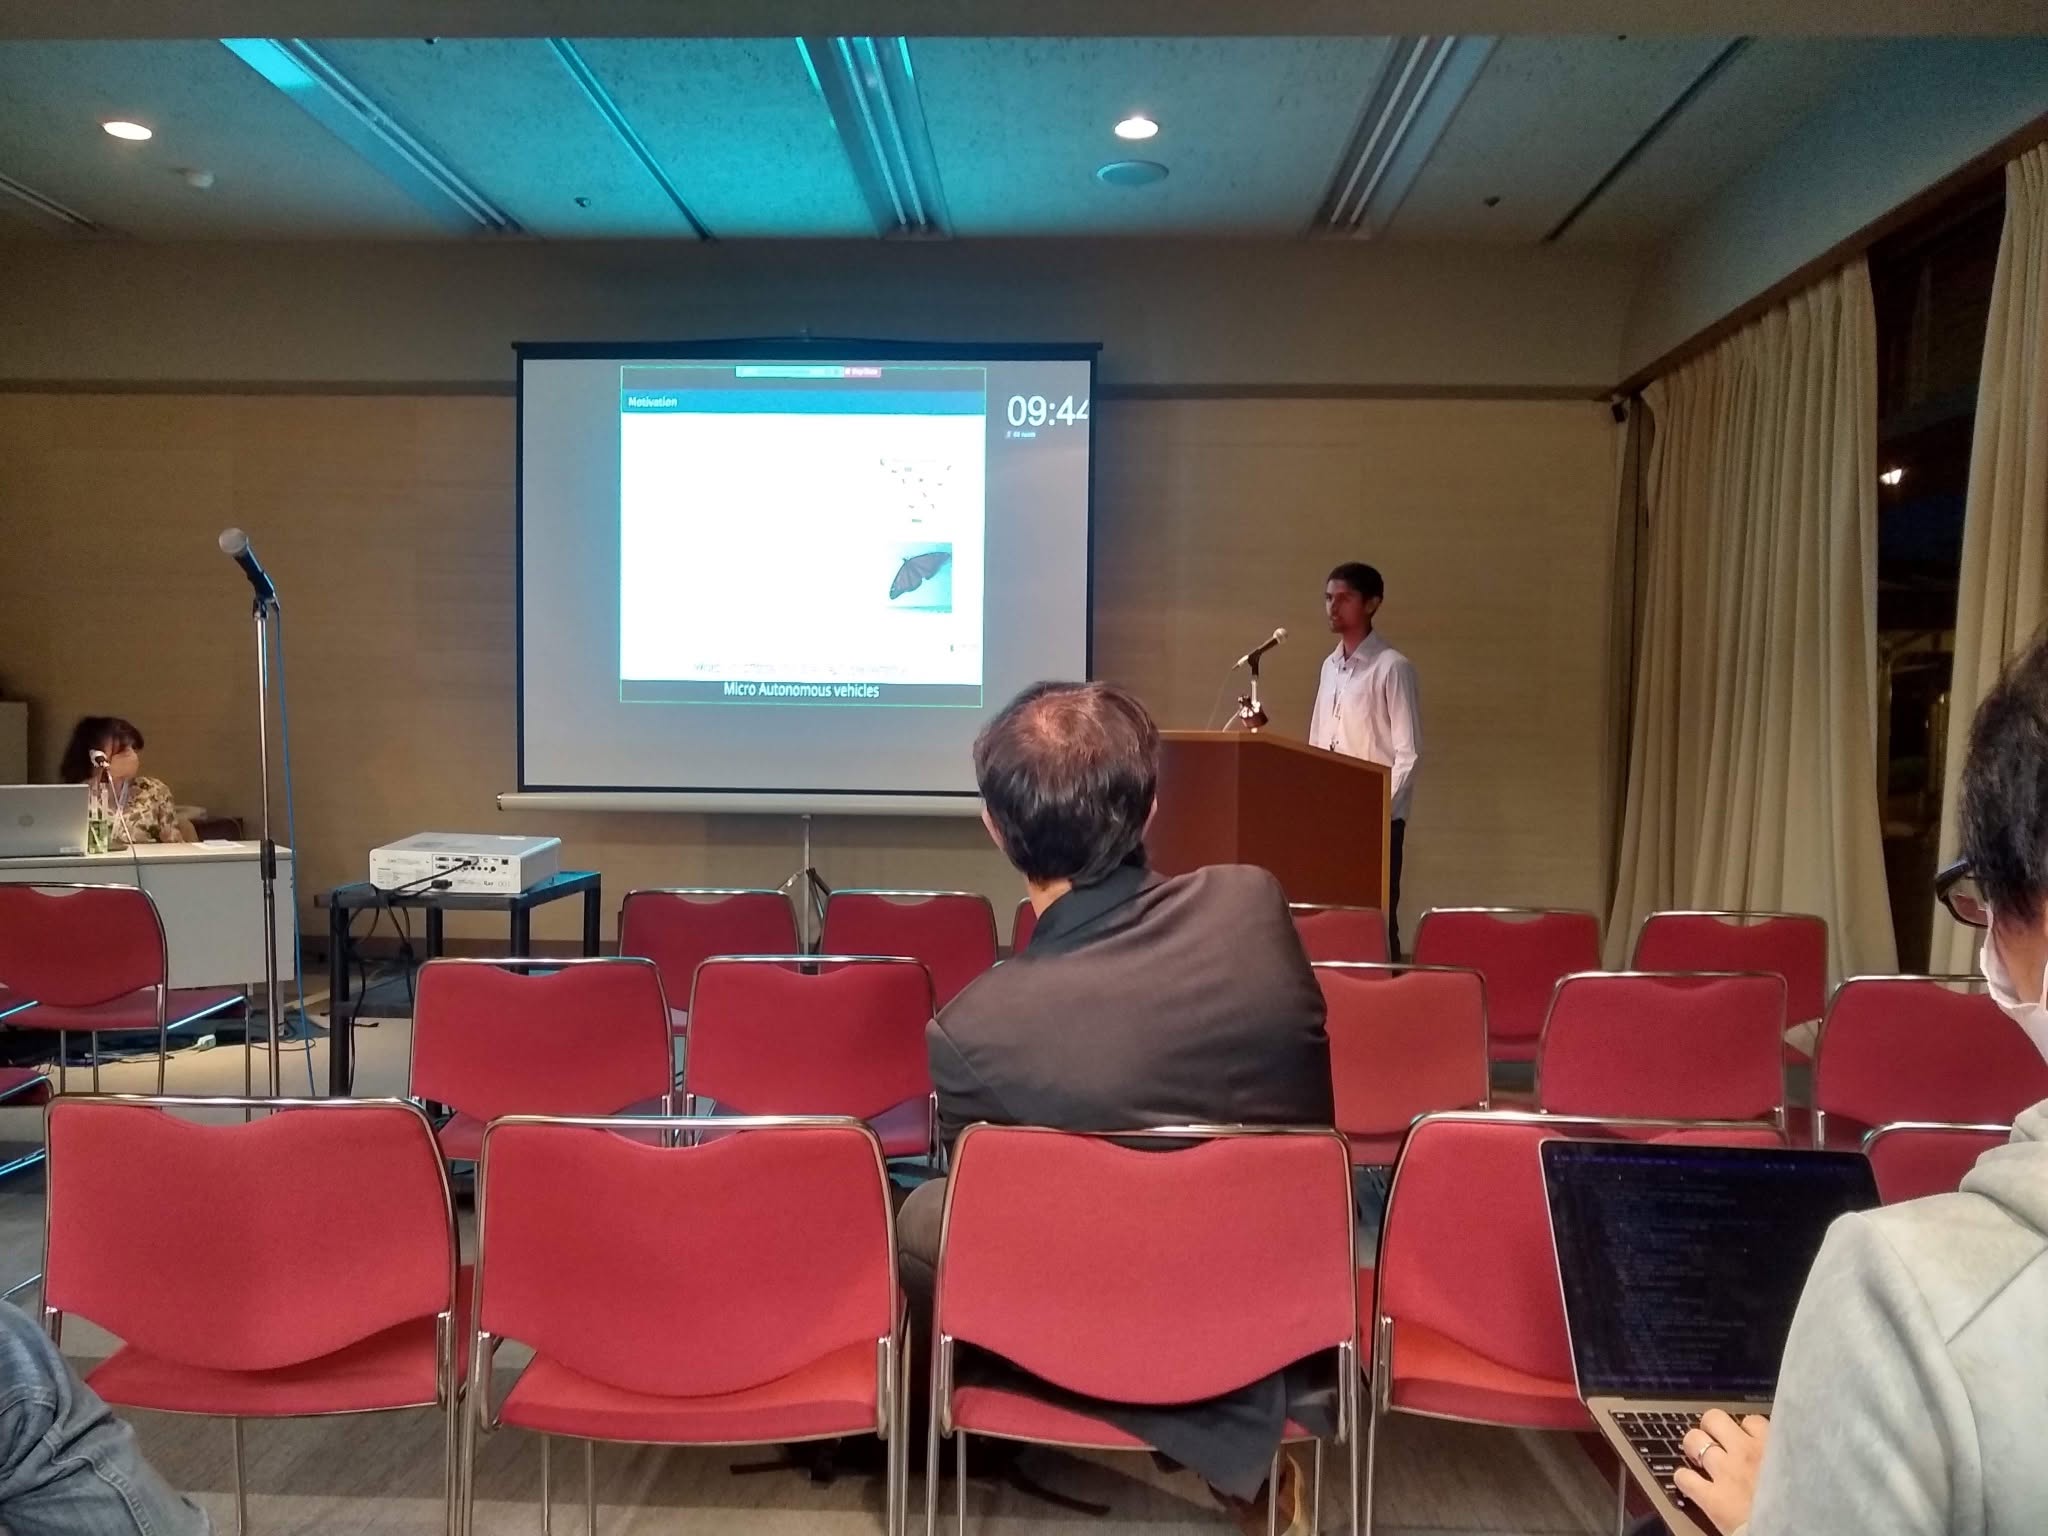

Tejaswi K. C. presented his research on imitation learning at IROS 2022 in Kyoto, Japan.
The work, “Constrained imitation learning for a flapping wing unmanned aerial vehicle,” studies learning-based control for flapping-wing flight while accounting for constraints. The paper appeared in IEEE Robotics and Automation Letters.