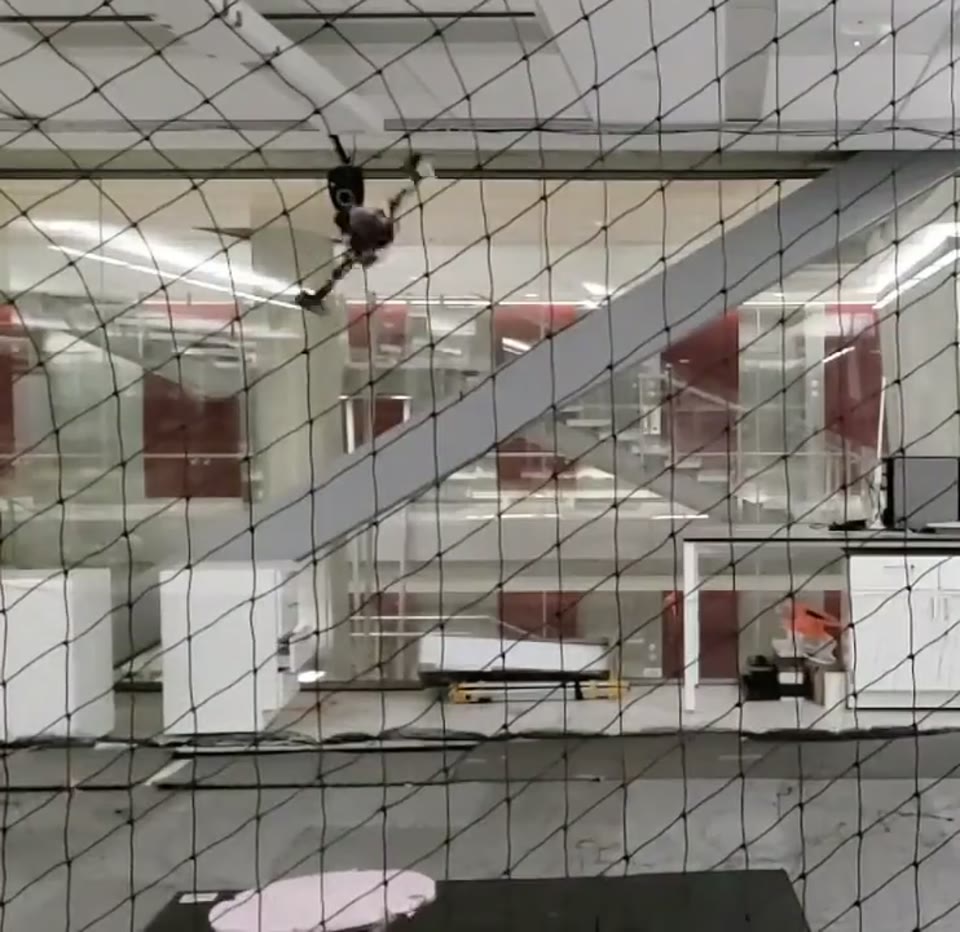
Quadrotor backflip in wind: a frame from the lab’s flight demonstration.

Mahdis Bisheban demonstrated a quadrotor backflip under wind disturbances. The experiment illustrates the lab’s interest in testing agile flight control in the presence of external disturbances.

The original Facebook announcement includes the flight video.
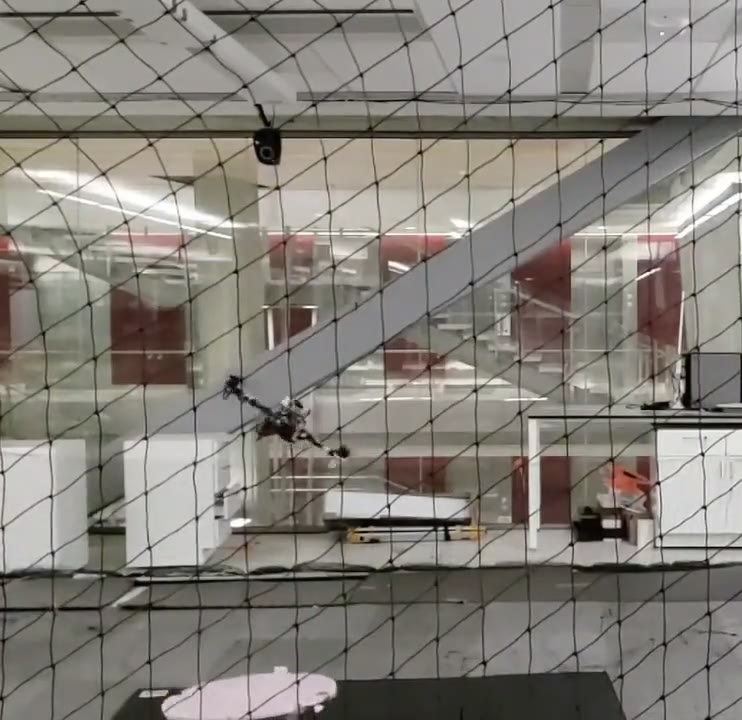
Another frame from the same backflip demonstration, showing a different stage of the maneuver.

Original FDCL announcement — March 2, 2019