NSF Funds Edge–Cloud Research for Autonomous Vehicles
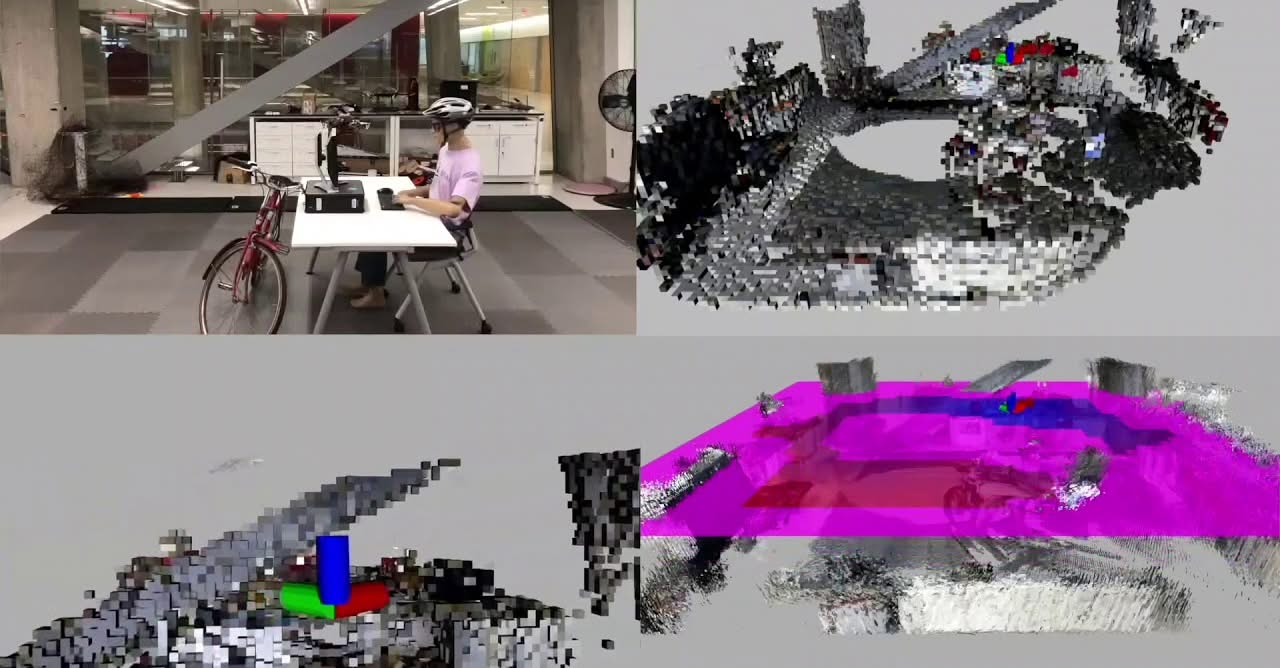
Research context: FDCL’s autonomous aerial exploration and mapping demonstration, shared in July 2018.
FDCL received a grant through the National Science Foundation’s Cyber-Physical Systems program for “Edge-Cloud Support for Predictable, Global Situational-Awareness for Autonomous Vehicles.”
The project connects autonomous-vehicle research with computing support for situational awareness.
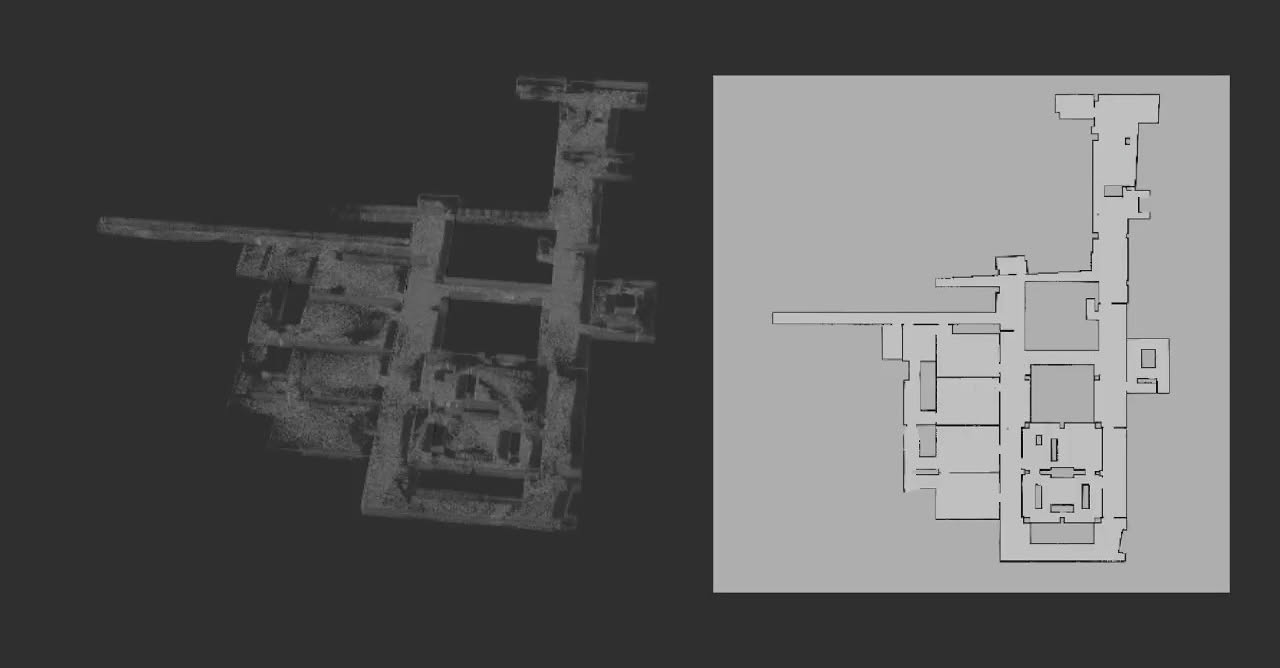
Research context: a multi-vehicle mapping demonstration shared in February 2018. These examples illustrate lab capabilities relevant to autonomous-vehicle situational awareness; they are not presented as results of the newly announced grant.