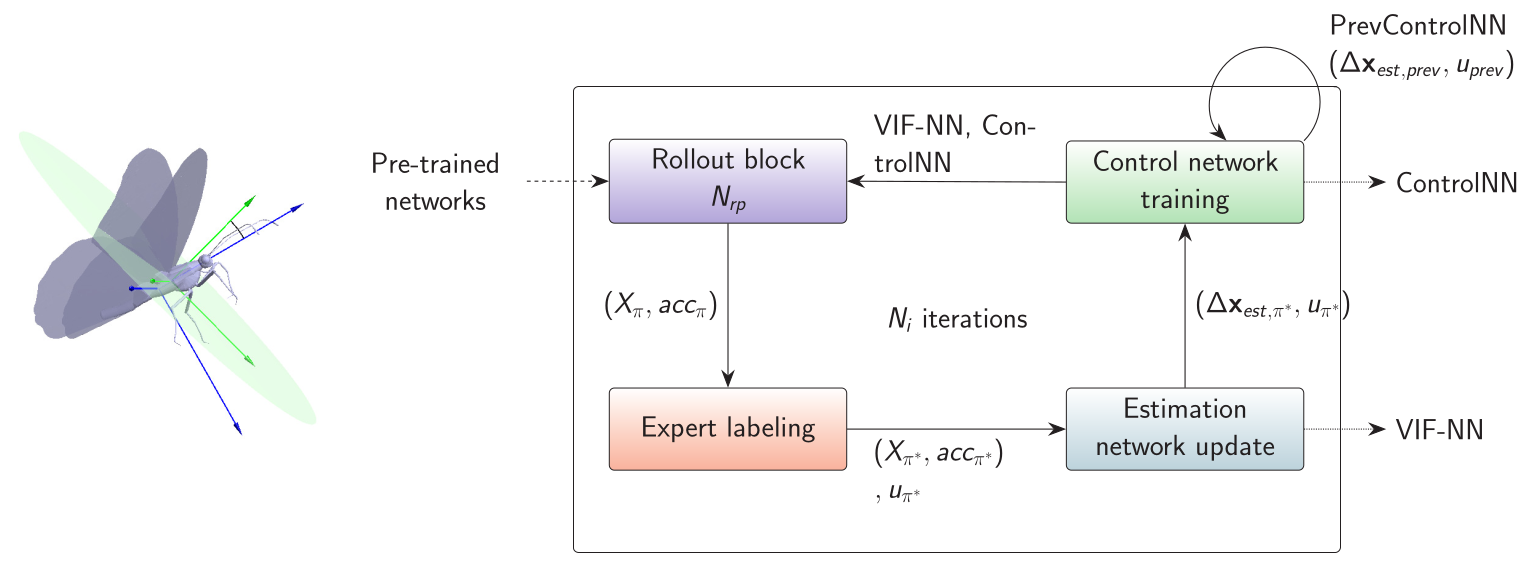
Research context from FDCL’s overview of butterfly-inspired flight dynamics and control.

FDCL highlighted Tejaswi K. C.’s work on “Dynamics and Control of a Flapping Wing UAV with Abdomen Undulation Inspired by Monarch Butterfly.”

The demonstration explores how abdomen motion can be incorporated into the dynamics and control of a flapping-wing vehicle. The original announcement provides the associated demonstration.
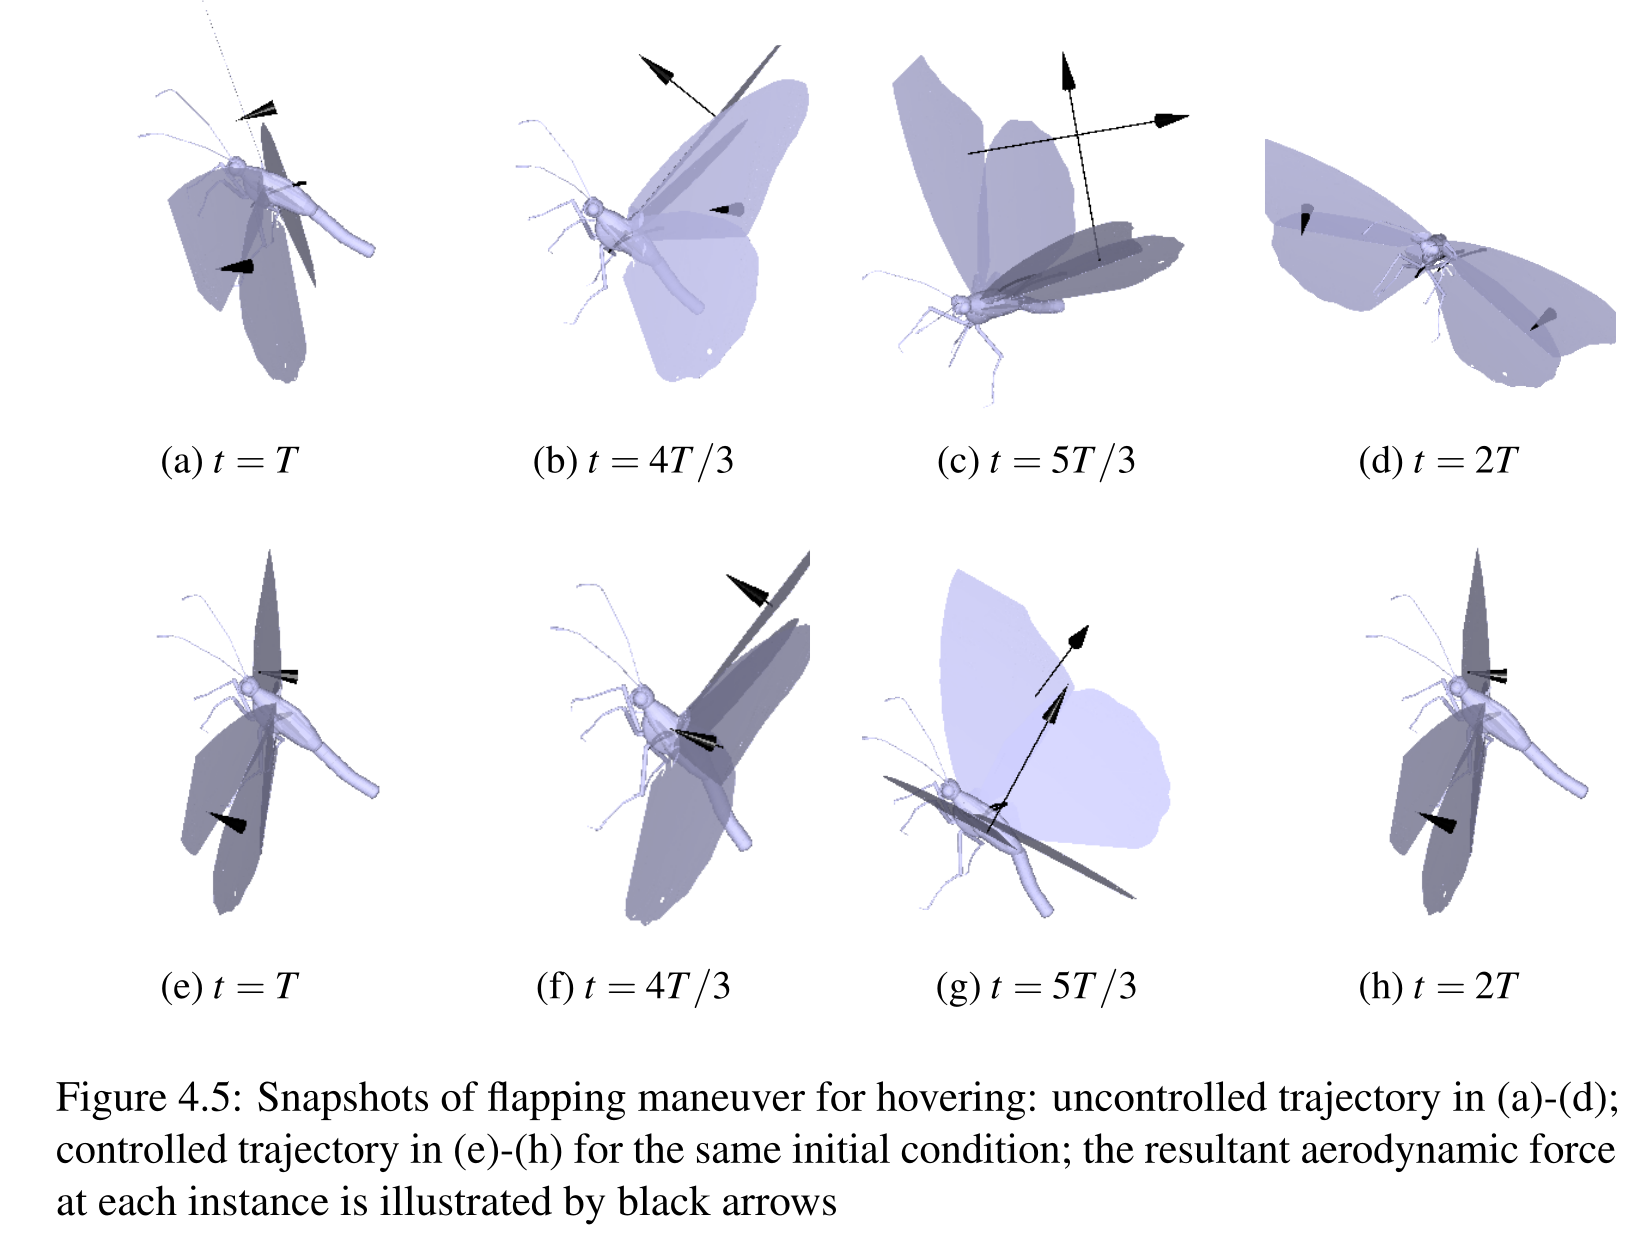
A modeled flapping cycle showing coordinated wing and body motion.

Original FDCL announcement — March 31, 2020

Written by

Taeyoung Lee

Taeyoung Lee is a professor in the Department of Mechanical and Aerospace Engineering at The George Washington University, with a courtesy appointment in Computer Science. He directs the Flight Dynamics and Control Laboratory and joined GW in 2011 after serving on the faculty at the Florida Institute of Technology. He earned his Ph.D. in Aerospace Engineering and M.S. in Mathematics from the University of Michigan in 2008.