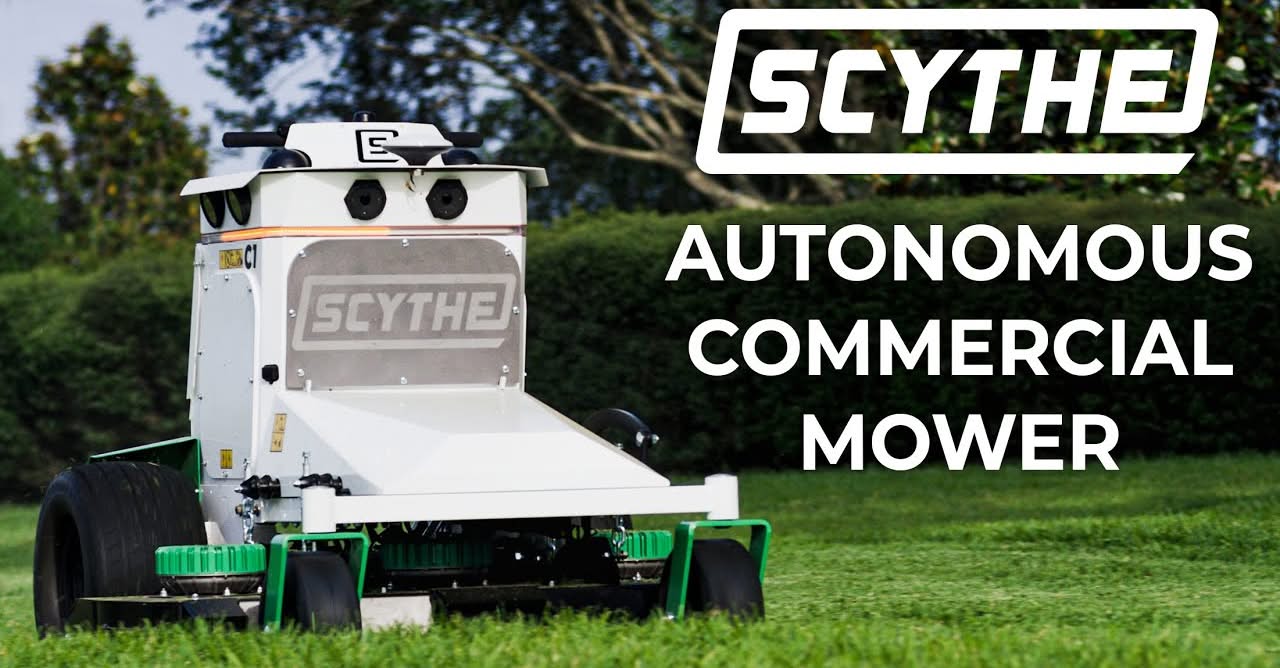

FDCL highlighted alumnus Evan Kaufman’s work on trajectory generation and control at Scythe. The lab shared the company’s demonstration video, “Scythe. It cuts.”
The project offers an example of control and autonomy research applied to robotic mowing.
