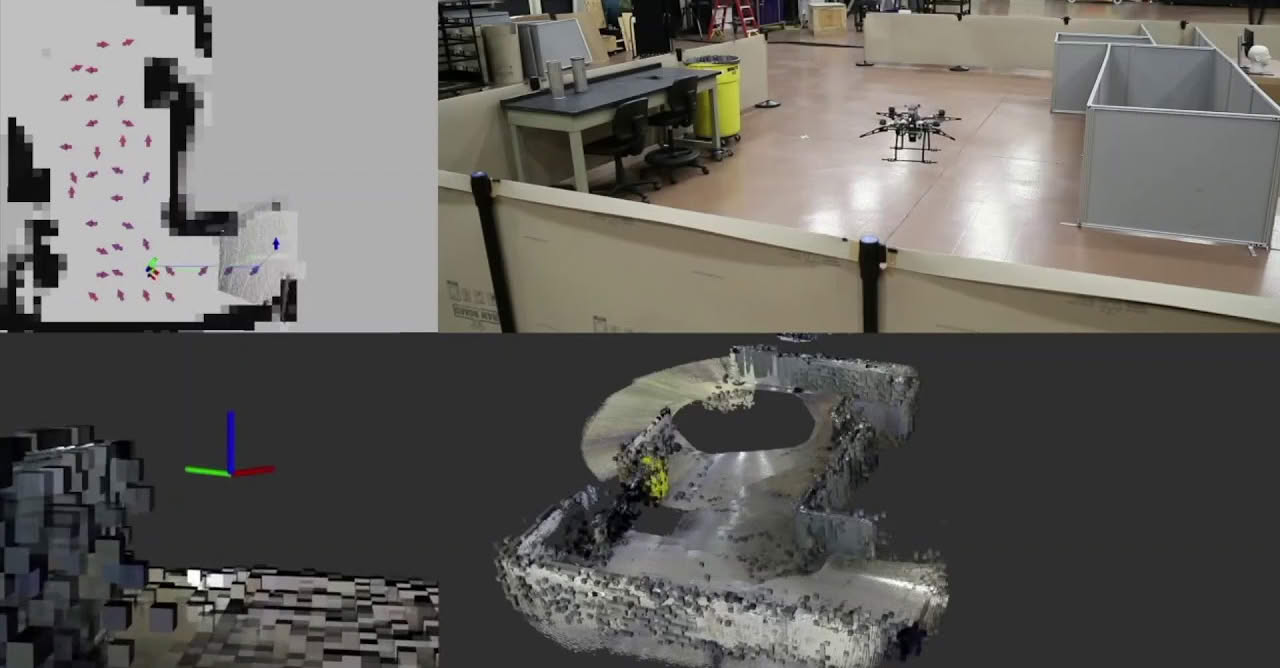
Research context: FDCL’s later autonomous mapping demonstration at NRL, shared in December 2017
Research context: FDCL’s later autonomous mapping demonstration at NRL, shared in December 2017. This illustrates the research area of the archived 2016 position.

In May 2016, FDCL advertised a postdoctoral position in autonomous exploration. The project focused on motion planning and control for multiple aerial vehicles cooperatively exploring an unknown area, drawing on estimation, mapping, SLAM, and flight experiments.

This is an archived recruitment announcement. For current opportunities, visit Join the Lab.
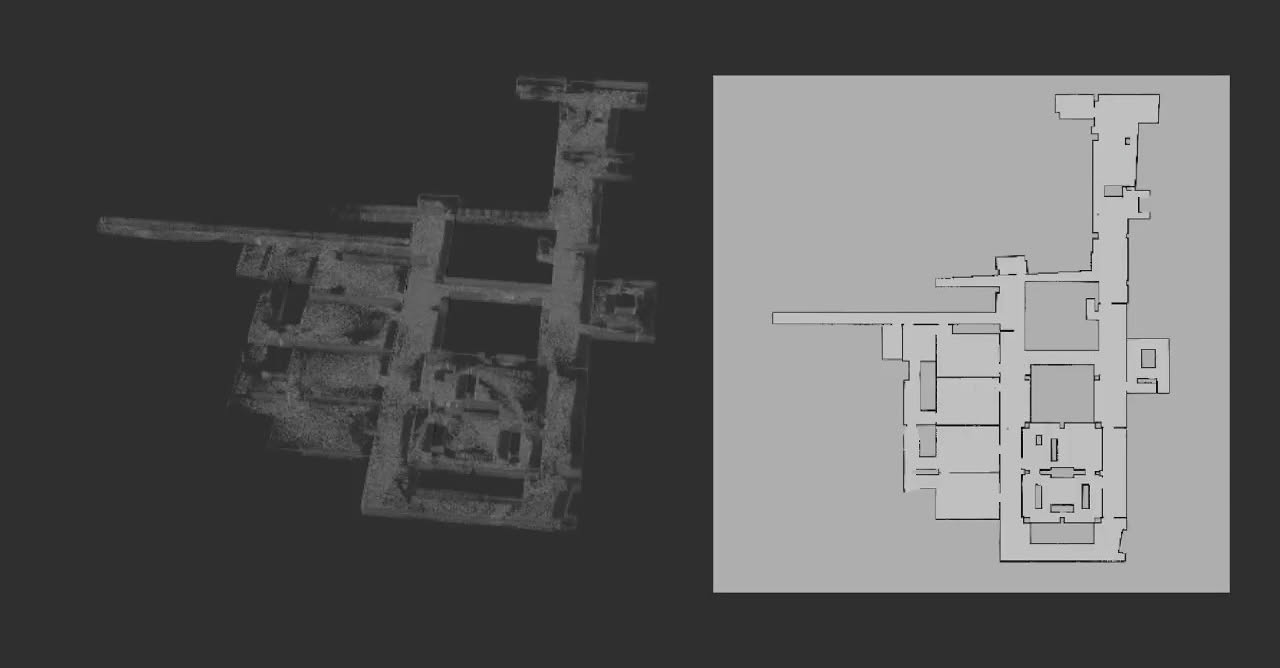
Research context: the lab’s multi-vehicle mapping demonstration, shared in February 2018.

Original FDCL announcement — May 20, 2016