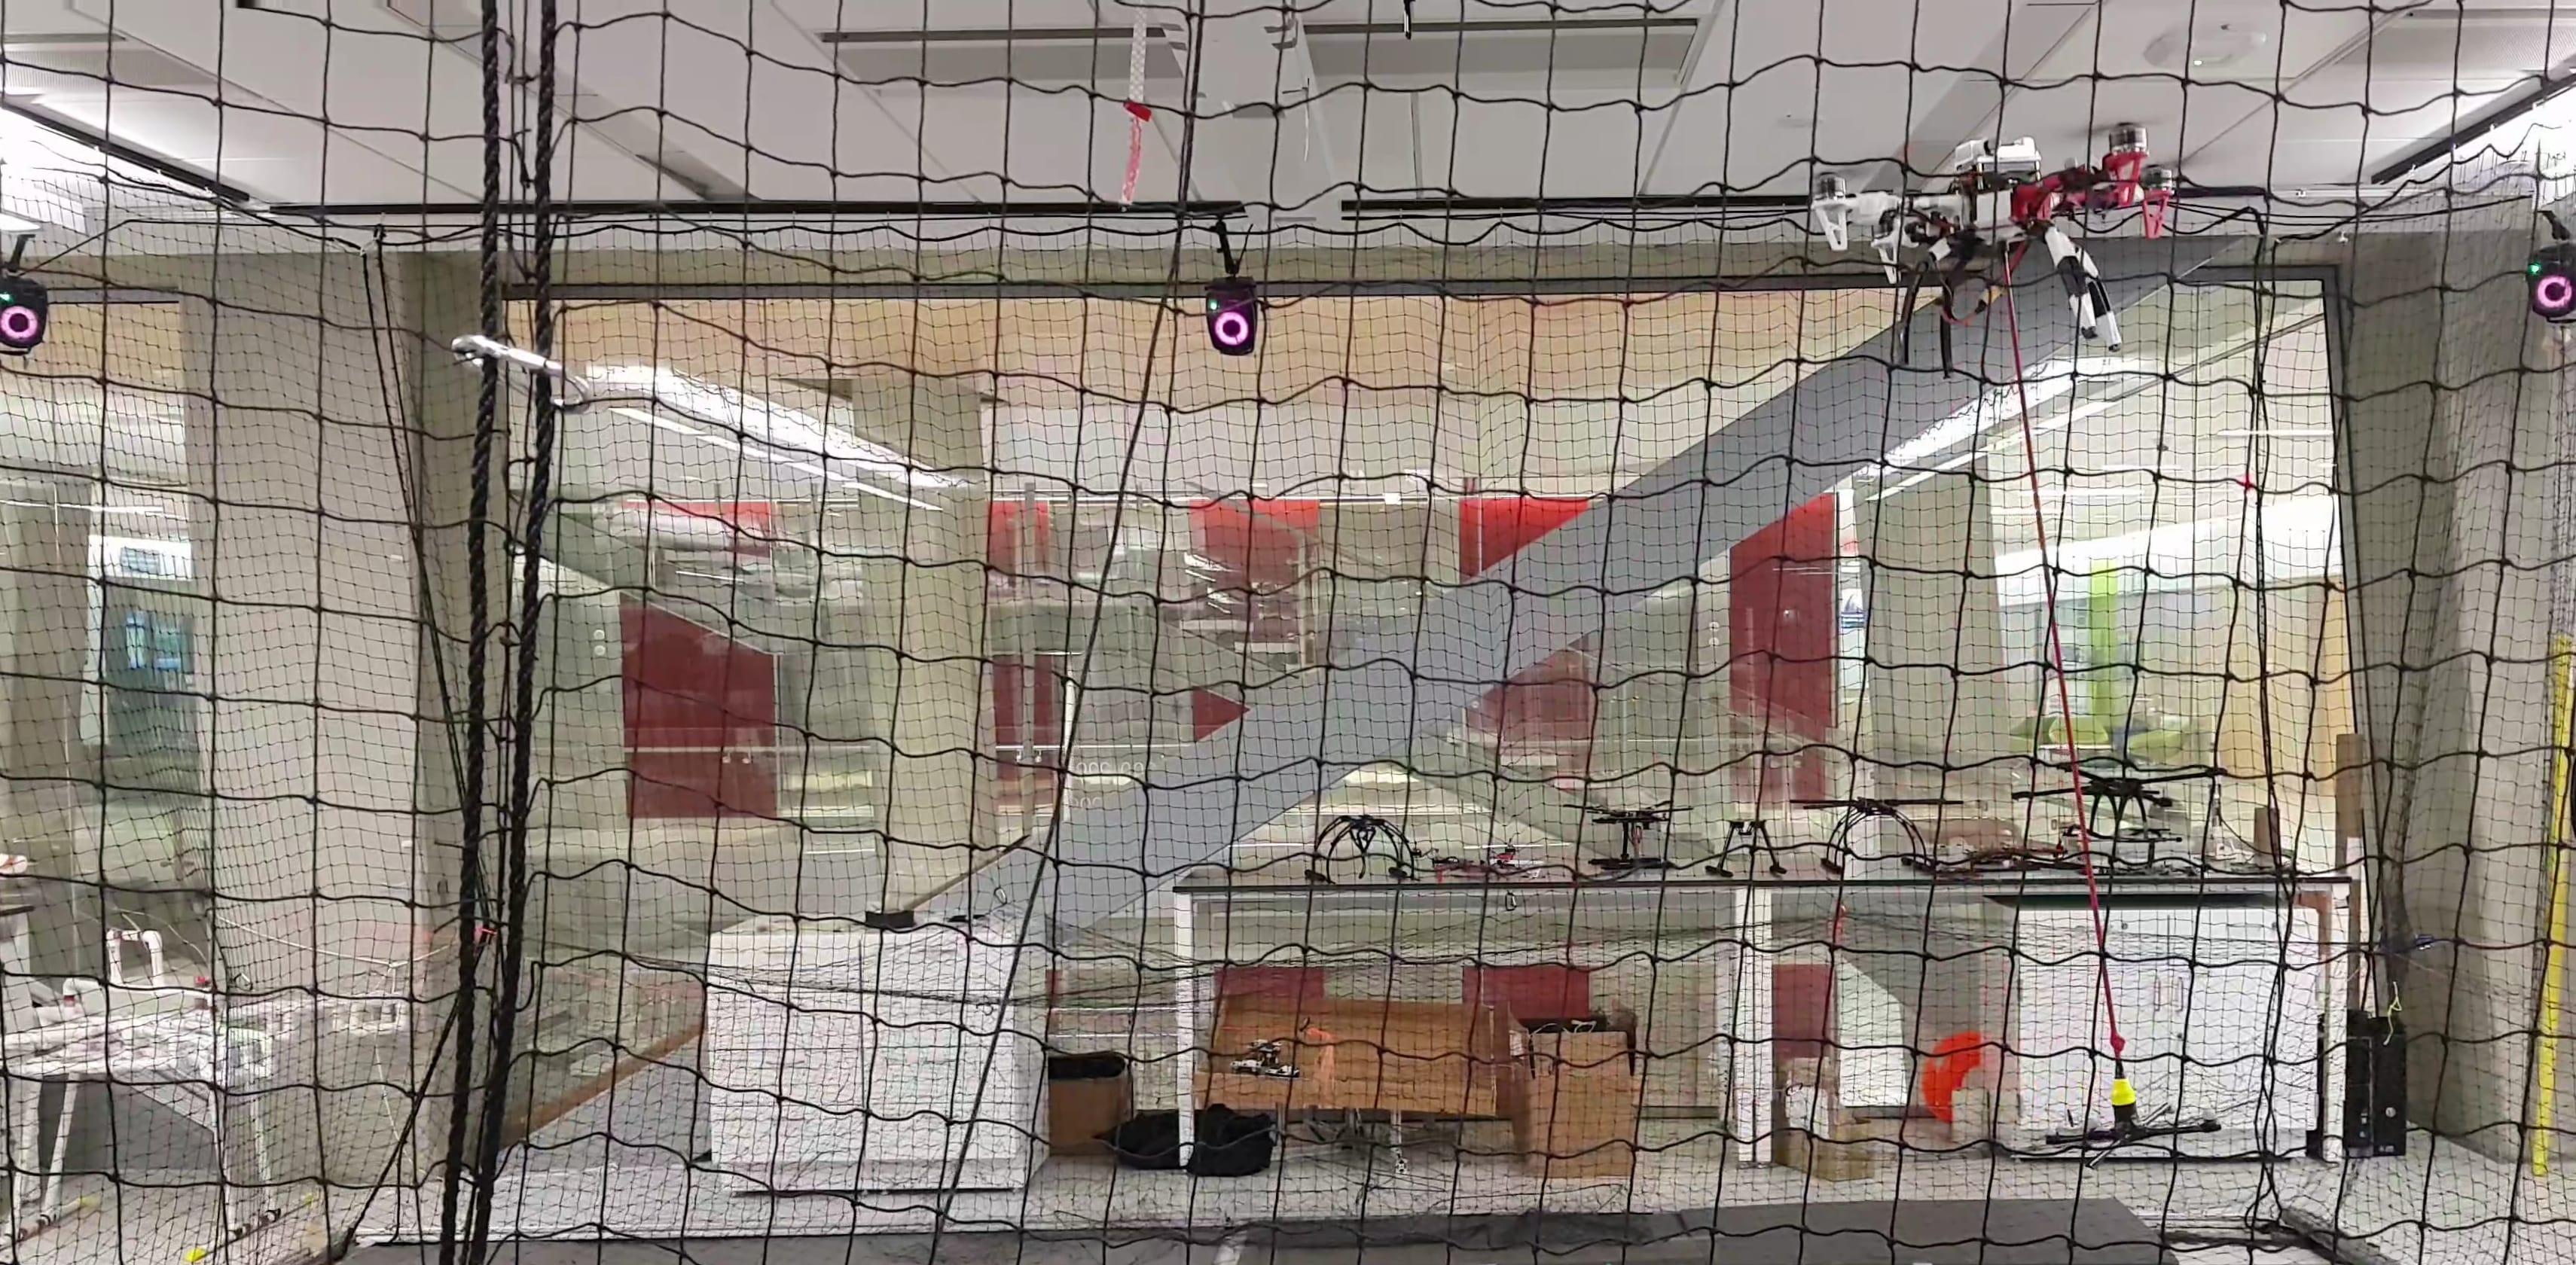
Farhad Goodarzi conducted research in geometric control and cooperative aerial transportation.
Lab affiliation: 2011–2015
Doctoral dissertation
Geometric Nonlinear Controls for Multiple Cooperative Quadrotor UAVs Transporting a Rigid Body
Ph.D., 2015